About me.
I am a Ph.D. candidate at the Northwestern University Center for Robotics and Biosystems.
I am a researcher in the Interactive and Emergent Autonomy Lab, advised by Dr. Todd Murphey.
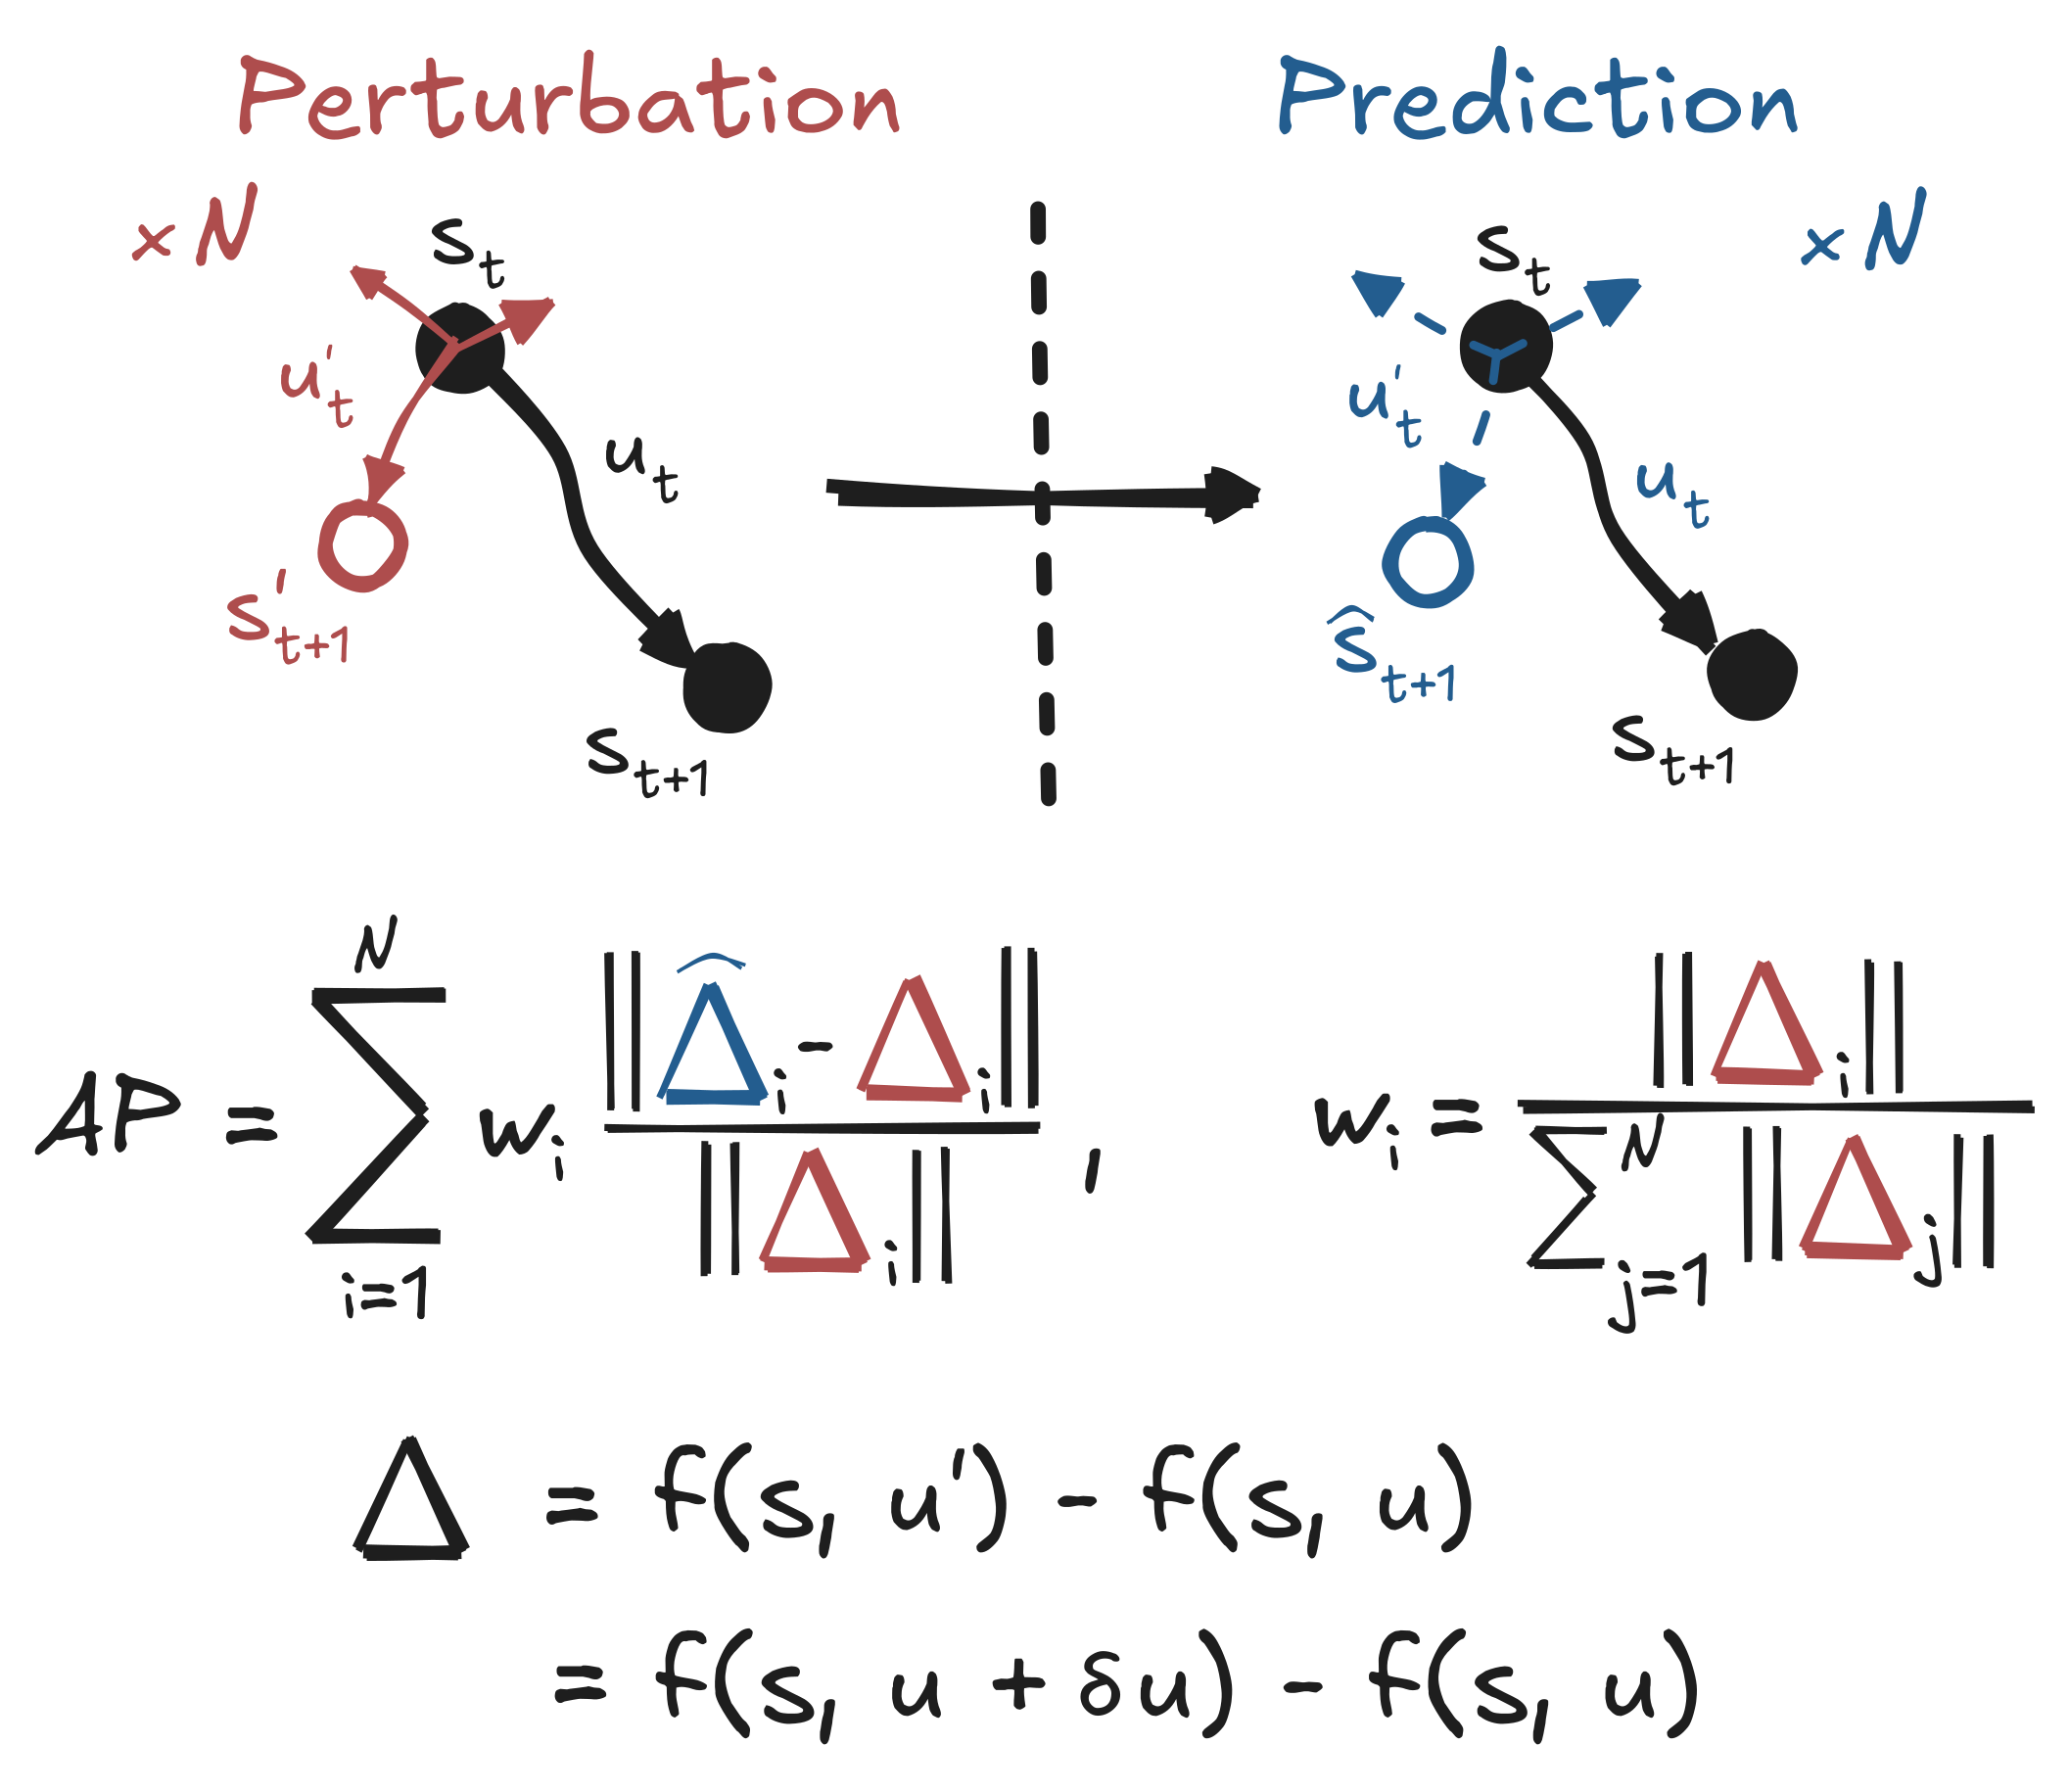
My research asks how robots can collect their own data to learn better world models.
I integrate predictive uncertainty as an information-theoretic signal in the closed-loop system of perception, learning, and action for online, active learning on hardware.
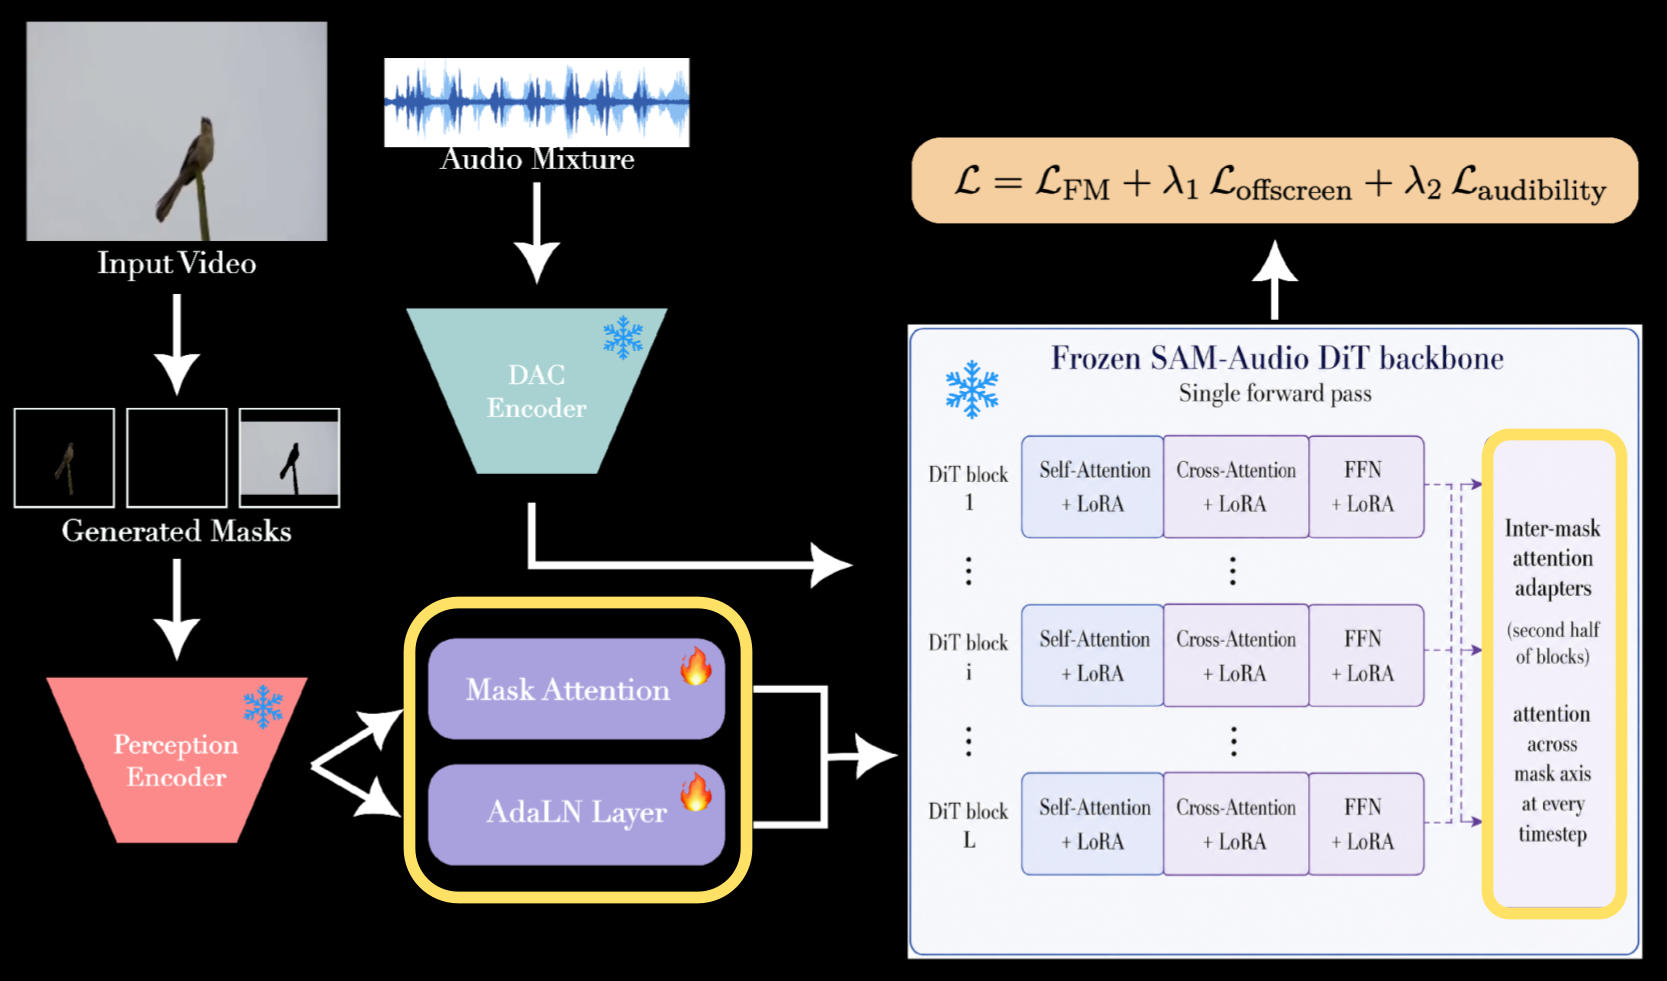
Before this, I worked on active perception with NeRFs and Gaussian Splatting and on fast ergodic exploration. Through internships at Honda Research Institute and Dolby, I also worked on multi-agent coordination, audio-visual perception, and fine-tuning multimodal foundation models.
Research Papers


Projects
-
NeRFs | Trajectory Optimization | Hardware

PATO: Perception-Aware Trajectory Optimization for Active NeRFs
-
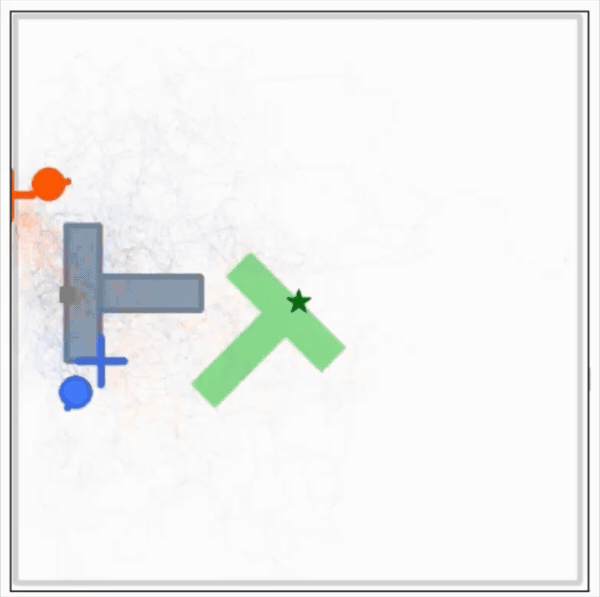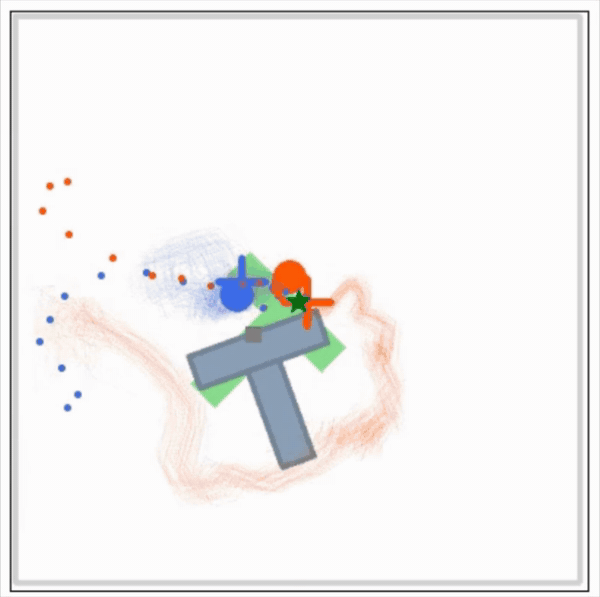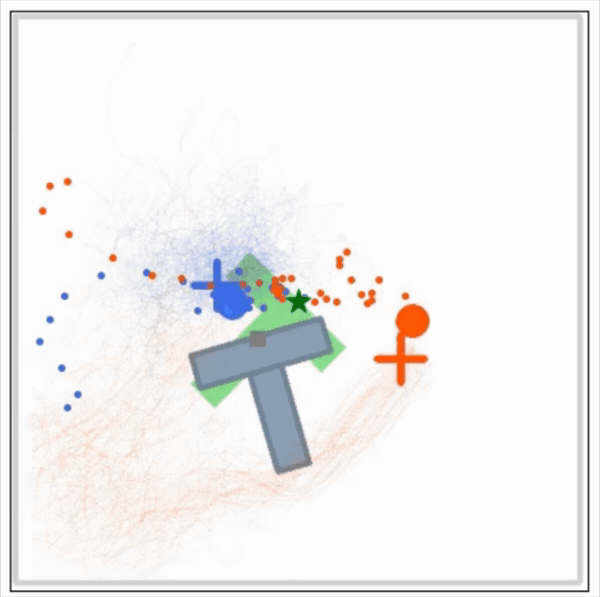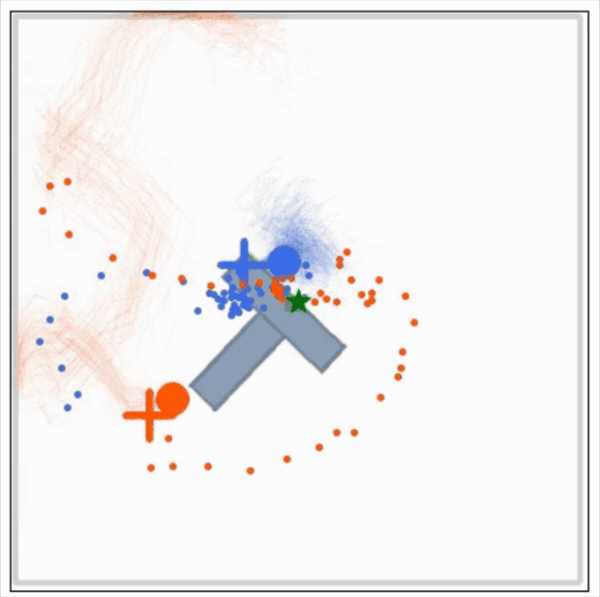
World Models | Data Collection | Information Theory
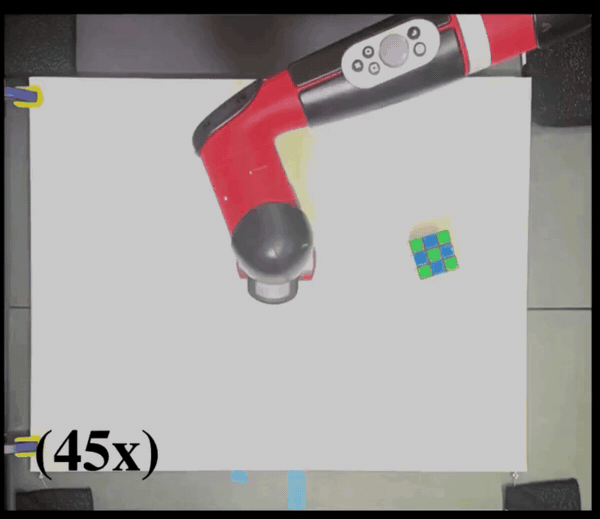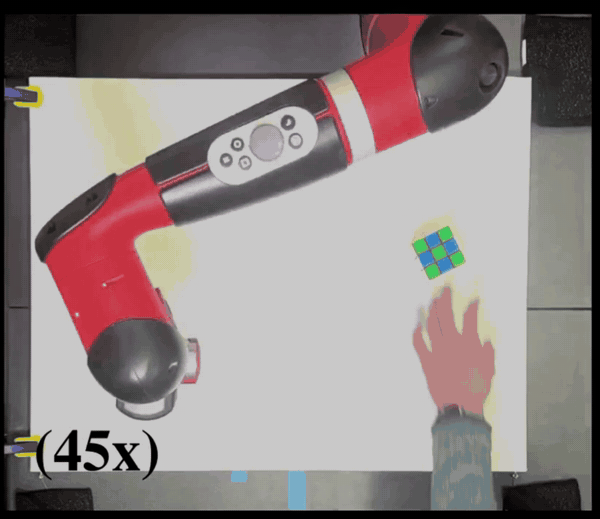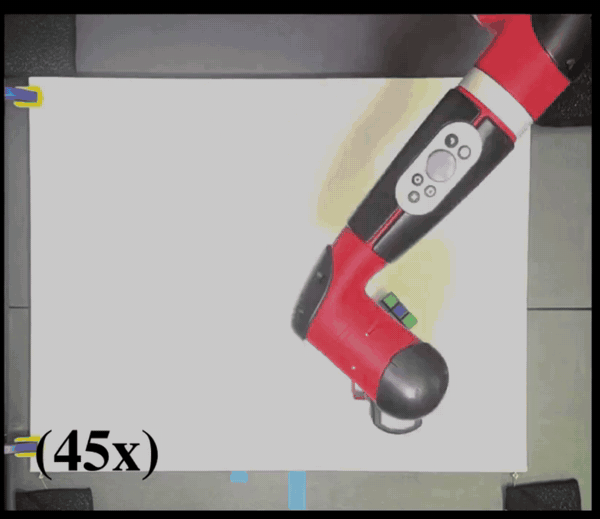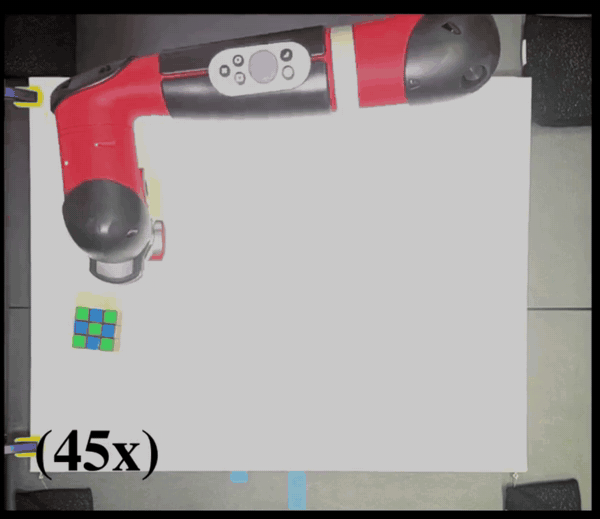
Information-Theoretic Data Collection for Affordance Discovery in World Models
-
ML | Variational Autoencoders

Control and Planning in the Latent Space
-
ROS2 | MoveIt | Search

Bimanual Manipulation for Coverage
-
ROS2 | C++ | EKF

EKF SLAM on a TurtleBot
-
ROS2 | MoveIt | Computer Vision
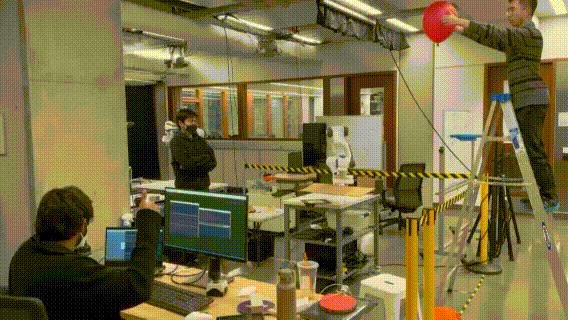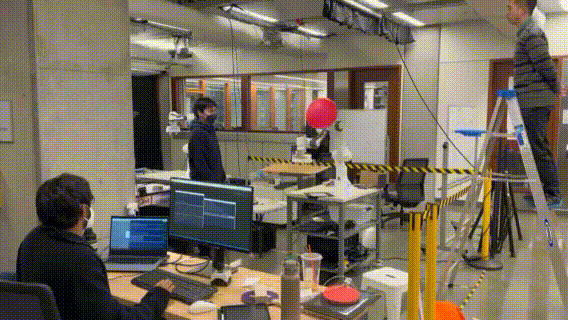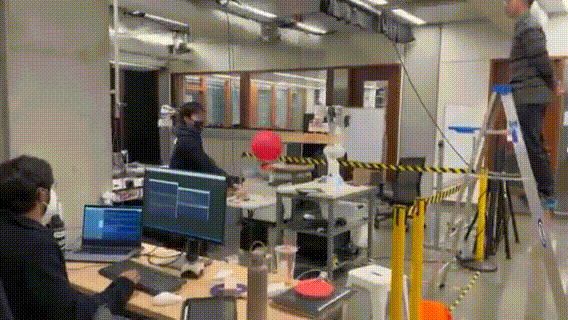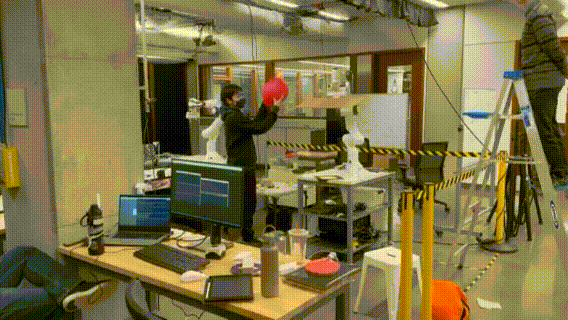
Balloon Volleyball with a 7-DOF Robot Arm